UGV Beast

Height

122 mm without pan-tilt; 252 mm with PT camera

Weight

2.034 kg without pan-tilt; 2.35 kg with PT camera

Speed

0.35 m/s

Research Available

UGV Beast

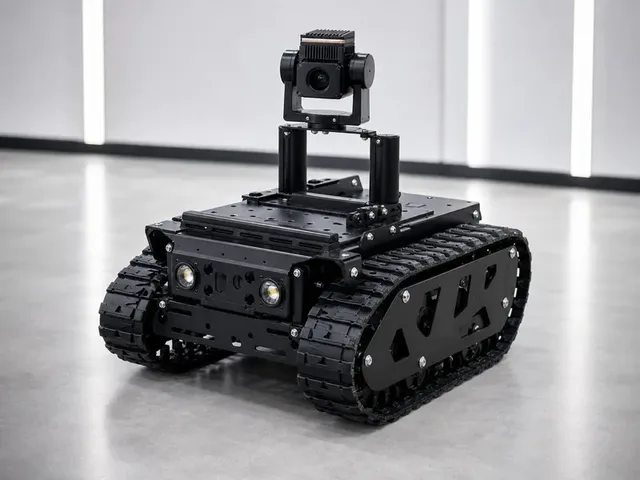
Waveshare's UGV Beast is an open-source off-road tracked AI robot platform for Raspberry Pi 4B or Raspberry Pi 5 developers. The official store page and wiki describe a dual-controller architecture: the Raspberry Pi handles higher-level AI vision, WebRTC browser control, JupyterLab tutorials, and strategy code while an ESP32 sub-controller handles motor PID, IMU data, pan-tilt/LED control, OLED status, battery sensing, and ESP-NOW communication. The tracked aluminum chassis adds independent suspension, zero-radius turning, optional 2-DOF pan-tilt with a 5MP 160-degree camera, OpenCV/MediaPipe demos for face, object, color, gesture, and line tracking, and hardware expansion for LiDAR, 4G/5G, audio, and GPIO peripherals. It is a maker and research platform rather than a consumer home-helper robot, but it clears ui44's bar through its open software stack, dual-controller design, computer-vision demos, and rugged mobile-robot hardware.
Listed price

$265

Official Waveshare store page lists UGV Beast kit variants from US$264.99 to US$501.99 depending on Raspberry Pi 4B/5, pan-tilt, and accessory configuration; 18650 batteries are not included.

Release window

Apr 21, 2026

Current status

Available

Waveshare

Last verified

Jul 3, 2026

Share this robot

Open a plain share composer on X or Bluesky for this robot profile.

Technical overview

Core specifications and system stack

A fast read on the mechanical profile, sensing package, and listed platform details for UGV Beast.

Technical Specifications

Height

122 mm without pan-tilt; 252 mm with PT camera

Weight

2.034 kg without pan-tilt; 2.35 kg with PT camera

Dimensions

232 x 197 x 122 mm base; 232 x 197 x 252 mm with PT camera

Battery Life

Not officially disclosed; uses 3x 18650 lithium cells with a 3S UPS module, batteries not included

Charging Time

Not officially disclosed; UPS module supports charging and discharging at the same time

Max Speed

0.35 m/s

Operational profile

How this robot is configured

Capabilities

14

Connectivity

6

Key capabilities

Open-source mobile robotics platformOff-road tracked chassis with independent suspensionDual-controller Raspberry Pi + ESP32 architectureBrowser-based WebRTC remote control and video streamingOpenCV color recognition and automatic targetingFace detection and media captureObject recognition demosGesture recognition with MediaPipe

Listed platforms & ecosystem

Raspberry Pi 4BRaspberry Pi 5Debian BookwormROS2 HumblePythonFlask

About the UGV Beast

6Protocols14CapabilitiesUSD $265Listed Price

The UGV Beast is a Research robot built by Waveshare. Waveshare's UGV Beast is an open-source off-road tracked AI robot platform for Raspberry Pi 4B or Raspberry Pi 5 developers. The official store page and wiki describe a dual-controller architecture: the Raspberry Pi handles higher-level AI vision, WebRTC browser control, JupyterLab tutorials, and strategy code while an ESP32 sub-controller handles motor PID, IMU data, pan-tilt/LED control, OLED status, battery sensing, and ESP-NOW communication. The tracked aluminum chassis adds independent suspension, zero-radius turning, optional 2-DOF pan-tilt with a 5MP 160-degree camera, OpenCV/MediaPipe demos for face, object, color, gesture, and line tracking, and hardware expansion for LiDAR, 4G/5G, audio, and GPIO peripherals. It is a maker and research platform rather than a consumer home-helper robot, but it clears ui44's bar through its open software stack, dual-controller design, computer-vision demos, and rugged mobile-robot hardware.

The UGV Beast is listed at USD $265. Official Waveshare store page lists UGV Beast kit variants from US$264.99 to US$501.99 depending on Raspberry Pi 4B/5, pan-tilt, and accessory configuration; 18650 batteries are not included. See all Waveshare robots on the Waveshare page.

Spec Breakdown

Detailed specifications for the UGV Beast

Height

122 mm without pan-tilt; 252 mm with PT camera

The listed height is 122 mm without pan-tilt; 252 mm with PT camera. Height alone does not establish working reach or clearance under furniture; check the documented operating configuration and required space.

Weight

2.034 kg without pan-tilt; 2.35 kg with PT camera

The listed weight is 2.034 kg without pan-tilt; 2.35 kg with PT camera. Weight alone does not establish locomotion, stability or safety around people. Check handling requirements and the model’s documented operating limits.

Dimensions

232 x 197 x 122 mm base; 232 x 197 x 252 mm with PT camera

The overall dimensions of 232 x 197 x 122 mm base; 232 x 197 x 252 mm with PT camera are a recorded size entry. Check which axes and configuration it covers: a height-only entry does not establish width, depth or passage fit. Planning clearance also requires the operating envelope, turning space, attachments and documented margins.

Maximum Speed

0.35 m/s default max speed

The recorded maximum-speed entry is 0.35 m/s default max speed. It does not establish sustained travel speed, terrain handling, or safe speed around people. Check the source's gait, operating mode, surface and load conditions before planning movement through a shared space.

Read this recorded AI entry alongside the model description and source notes for announcement or deployment context. A platform name alone does not establish implemented features, autonomy, or performance.

UGV Beast Sensor Suite

The profile lists the sensor descriptions below. These entries do not establish physical sensor counts, sensor fusion, redundancy, or performance.

Consult the linked profile sources for hardware configuration and tested behavior. A technology label alone does not verify an operating capability.

Explore sensor technologies: components glossary · full components directory

UGV Beast Use Cases & Applications

Research robots serve as platforms for advancing robotics science and engineering. They enable researchers to test theories about locomotion, manipulation, perception, and human-robot interaction in controlled and real-world environments.

Recorded Capabilities

The UGV Beast record lists 14 capabilities. Keep any announcement or demonstration qualifiers attached to these entries; the count alone does not establish practical performance.

Open-source mobile robotics platform
Off-road tracked chassis with independent suspension
Dual-controller Raspberry Pi + ESP32 architecture
Browser-based WebRTC remote control and video streaming
OpenCV color recognition and automatic targeting
Face detection and media capture
Object recognition demos
Gesture recognition with MediaPipe
Vision line tracking for autonomous-driving tutorials
2-DOF camera pan-tilt control and vertical stabilization
ESP-NOW multi-robot communication
JupyterLab and Python development workflow
ROS2 Humble tutorial support
LiDAR, GPIO, audio, and cellular expansion

These are the capabilities listed in the profile. Hardware configuration and demonstrated performance should be checked against the linked sources.

Listed Platforms & Ecosystem

These are the platforms, communities, or ecosystem relationships listed in the profile. A listed name or protocol alone does not confirm home-device interoperability or automation support.

Raspberry Pi 4B Raspberry Pi 5 Debian Bookworm ROS2 Humble Python Flask WebRTC OpenCV MediaPipe JupyterLab ESP-NOW

UGV Beast Capabilities

14

Capabilities

AI

Raspberry Pi 4B/5 host…

Open-source mobile robotics platform
Off-road tracked chassis with independent suspension
Dual-controller Raspberry Pi + ESP32 architecture
Browser-based WebRTC remote control and video streaming
OpenCV color recognition and automatic targeting
Face detection and media capture
Object recognition demos
Gesture recognition with MediaPipe
Vision line tracking for autonomous-driving tutorials
2-DOF camera pan-tilt control and vertical stabilization
ESP-NOW multi-robot communication
JupyterLab and Python development workflow
ROS2 Humble tutorial support
LiDAR, GPIO, audio, and cellular expansion

Listed Connectivity & Voice Systems

The UGV Beast profile lists the following communication and voice-system descriptions.

UGV Beast Technology Stack Overview

The UGV Beast by Waveshare has the following technology descriptions in its profile. The physical platform features a height of 122 mm without pan-tilt; 252 mm with PT camera, a weight of 2.034 kg without pan-tilt; 2.35 kg with PT camera, a top speed of 0.35 m/s default max speed, providing the foundation on which this technology stack operates.

Who Should Consider the UGV Beast?

Target Audience

Research robots are acquired by universities, government labs, and corporate R&D departments. They serve as experimental platforms for developing new algorithms, testing locomotion strategies, and advancing the field of robotics. Some are also used for educational purposes.

Key Considerations

Open-source software compatibility (ROS/ROS 2), sensor modularity, programmability, available SDK/API quality, community support, and published research papers using the platform are key factors. Documentation quality and the ability to modify both hardware and software are essential for research use.

Listed pricing

The UGV Beast is listed at USD $265. Official Waveshare store page lists UGV Beast kit variants from US$264.99 to US$501.99 depending on Raspberry Pi 4B/5, pan-tilt, and accessory configuration; 18650 batteries are not included.

Availability

Available

The UGV Beast is listed as Available, indicating an ordering listing. The label does not confirm current stock, regional access, or shipping dates. Check Waveshare's current ordering terms and the recorded sales notes for details.

UGV Beast: Strengths & Trade-offs

Recorded features and considerations to assess

Recorded features to assess for the UGV Beast

Recorded capability range

The UGV Beast record lists 14 capabilities. Review their qualifiers and supporting evidence for the tasks you need. The number of entries does not establish workflow coverage, reliability, or the ability to replace other robots.

Listed Available

The UGV Beast is listed as Available, indicating an ordering listing. The label does not confirm current stock, regional access, or shipping dates. Check Waveshare's current ordering terms and the recorded sales notes for details.

Note: This strengths and trade-offs assessment is based on the UGV Beast's documented specifications as tracked in the ui44 database. Real-world performance depends on deployment conditions, firmware maturity, and environmental factors. For the most current information, check the Waveshare manufacturer page or visit the official source. Use the comparison tool to evaluate these trade-offs against competing robots in the same category.

How Research Robot Technology Works

Understanding the engineering behind this category

Research robots serve a fundamentally different purpose than commercial or consumer models. They are platforms for discovery — enabling scientists and engineers to test theories, develop algorithms, and push the boundaries of what robots can do. The technology in research robots prioritizes openness, flexibility, and access to raw data over consumer-friendly packaging or commercial reliability. Understanding this distinction is important for anyone considering a research robot platform.

Navigation & Mobility

Research robots typically expose their navigation systems at a much lower level than commercial products. Researchers can access raw sensor data, modify SLAM algorithms, implement custom path planners, and test novel navigation approaches. ROS (Robot Operating System) and ROS 2 compatibility is standard, providing a common framework for sharing navigation modules across the research community. This openness enables rapid iteration — a researcher can swap between different SLAM implementations, test new obstacle avoidance strategies, or develop entirely novel navigation paradigms without being locked into a vendor's proprietary stack.

The Role of AI

Research robots serve as physical testbeds for AI algorithms that may eventually appear in commercial products years later. Reinforcement learning, imitation learning, few-shot task learning, and human-robot interaction studies all require robot platforms that can execute AI-generated commands in the physical world. The gap between simulation (where training is cheap and fast) and reality (where physics is unforgiving) makes physical robot platforms essential for validating AI approaches. Research robots must support rapid deployment of new AI models without extensive integration work.

Sensor Fusion & Perception

Research platforms prioritize sensor modularity and data access. Standard mounting interfaces allow researchers to attach custom sensors alongside built-in ones. Raw sensor data streams (not just processed results) are accessible for developing novel perception algorithms. Precise time-stamping and synchronization across sensor streams enable accurate multi-modal fusion research. Many research robots include more sensors than strictly necessary for any single application, providing researchers with rich datasets for developing and testing new algorithms.

Power & Battery Management

Research robots balance operational runtime with practical lab use. Sessions of one to four hours are typical, with quick charging between experiments. Some research setups use tethered power for long-running experiments where battery limitations would interrupt data collection. Power monitoring and logging capabilities help researchers understand the energy costs of different behaviors and algorithms — important for developing efficient approaches that will eventually run on battery-constrained commercial systems.

Safety by Design

Research environments present unique safety challenges because robots are constantly being programmed with untested behaviors. Hardware safety limits (joint speed caps, force limits, emergency stops) must be robust regardless of software commands. Safety-rated monitored stop and speed monitoring ensure the robot cannot exceed safe operating parameters even when running experimental code. Collaborative operation standards apply when researchers work alongside the robot during experiments. Many labs implement layered safety with physical barriers for high-speed testing and open-area operation restricted to validated, lower-risk behaviors.

What's Next for Research Robots

Research robot platforms are becoming more accessible and capable. Cloud robotics enables remote experiment execution and shared datasets. Digital twins and high-fidelity simulators reduce the need for physical hardware time while improving sim-to-real transfer. Standardized benchmarks and open datasets enable fair comparison of results across labs. The democratization of robotics research — through lower-cost platforms, open-source software, and cloud infrastructure — is expanding who can contribute to advancing the field.

These are category-level technology examples; they do not establish the capabilities of the UGV Beast. For its recorded hardware details, see the sensor analysis and connectivity sections above. Check model-specific documentation from Waveshare for supported behavior, or use the components glossary to look up terminology.

UGV Beast in the Research Market

How this robot compares in the research landscape

The UGV Beast is listed at USD $265. Official Waveshare store page lists UGV Beast kit variants from US$264.99 to US$501.99 depending on Raspberry Pi 4B/5, pan-tilt, and accessory configuration; 18650 batteries are not included.

The UGV Beast is listed as Available, indicating an ordering listing. The label does not confirm current stock, regional access, or shipping dates. Check Waveshare's current ordering terms and the recorded sales notes for details.

Head-to-Head Comparisons

Side-by-side specs, capability overlap analysis, and key differentiators.

For the full picture of Waveshare's portfolio and market strategy, visit the Waveshare manufacturer page.

Deployment Readiness and Procurement Signals for UGV Beast

What the public profile tells you, and what still needs direct vendor confirmation

From a buying and rollout perspective, the UGV Beast should be read as a research platform aimed at labs and development teams validating robotics workflows. ui44 currently tracks 14 capability signals and a last verification date of 2026-07-03. That mix gives buyers a useful first-pass picture, but it is still only the public layer of due diligence, especially when procurement, uptime, and support commitments are decided directly with Waveshare.

Commercial model

USD $265 list price

The UGV Beast is listed at USD $265. Official Waveshare store page lists UGV Beast kit variants from US$264.99 to US$501.99 depending on Raspberry Pi 4B/5, pan-tilt, and accessory configuration; 18650 batteries are not included.

Integration posture

6 connectivity options

The profile lists Wi-Fi and Ethernet via Raspberry Pi host, Bluetooth via Raspberry Pi host, ESP32 Wi-Fi / Bluetooth / ESP-NOW, Browser Web App with WebRTC video, USB gamepad receiver support, Optional 4G/5G module expansion. These labels do not establish APIs, fleet-management features, or workflow integration. These are the platforms, communities, or ecosystem relationships listed in the profile. A listed name or protocol alone does not confirm home-device interoperability or automation support.Recorded AI description: Raspberry Pi 4B/5 host running Debian Bookworm with open-source Flask/WebRTC and JupyterLab tutorials; OpenCV and MediaPipe demos cover color recognition, automatic targeting, face detection, object recognition, gesture control, and vision line tracking, while the ESP32 sub-controller handles real-time motion/sensor loops.

Spec disclosure

4/7 core specs public

ui44 currently has 4 of 7 core physical and operating specs filled in for this model, leaving 3 gaps that matter for deployment planning. Missing runtime, charge, speed, or payload details can materially change staffing and site-readiness assumptions.

The current profile is useful for scouting, but it still leaves meaningful operational unknowns. If this robot is heading toward a pilot or purchase discussion, the next step should be a structured vendor Q&A that fills the remaining runtime, charging, payload, safety, or integration blanks before anyone builds ROI assumptions around it.

If you want a faster apples-to-apples read, compare the UGV Beast against nearby alternatives in ui44's compare view, then cross-check the underlying AI, sensor, and subsystem terms in the components glossary. For manufacturer-level context, the Waveshare profile helps anchor this robot inside the wider product lineup.

Before you sign off on a pilot, confirm these points

  • Ask for real shift runtime under the intended workload, not just standby endurance.
  • Confirm how the charging workflow works in practice, including charger count, swap options, and expected downtime.
  • Clarify usable payload or tool-load limits before planning material handling or mounted accessories.
  • Check what safety, electrical, or deployment certifications exist for the region and task you care about.

Owning the UGV Beast: Setup, Maintenance & Tips

Practical guide from day one through years of ownership

Initial Setup

Research robot setup combines hardware assembly with software environment configuration. Unpack and assemble the platform following the manufacturer's documentation. Install the development framework — typically ROS or ROS 2 — and verify sensor connectivity. Calibrate all sensors using the manufacturer's tools and procedures. Set up the simulation environment (Gazebo, Isaac Sim, or equivalent) alongside the physical platform for parallel development. Establish version control for your experiment code and configuration. Document the initial calibration values and system state as your baseline for future reference. Plan network and computing infrastructure to handle the data rates your sensors will generate.

Ongoing Maintenance

Research robots need maintenance that preserves the precision required for valid experimental results. Regularly verify sensor calibration — drift in camera intrinsics or IMU biases can invalidate experiment data. Maintain clean workspace conditions to protect optical sensors. Document any hardware modifications or maintenance performed, as these can affect experimental reproducibility. Update software dependencies carefully, documenting versions used for each experiment. Joint and actuator wear in research robots that perform repetitive tasks should be monitored and factored into experimental design.

Software Updates & Long-Term Support

Research robot software updates require careful management to maintain experiment reproducibility. Document the exact software versions used for each experiment. Test updates in a separate environment before applying to your experiment platform. Contribute bug fixes and improvements back to the community when using open-source frameworks. Be aware that ROS and other framework updates may require code changes in your custom packages — budget time for integration testing after major framework updates.

Maximizing Longevity

Research robots often have longer productive lives than commercial products because they can be upgraded and repurposed. Extend your investment by maintaining clean mechanical and electrical systems, documenting all modifications for future lab members, and keeping spare parts for common wear items. When specific components become obsolete, community forums and lab networks can be valuable sources for replacements. Consider the platform's modularity when planning future research directions — a platform that can accept new sensors and actuators adapts to evolving research questions.

Find product and source links on the Waveshare page on ui44 or open Waveshare's official source. Use model-specific manufacturer documentation for setup, cleaning, and service instructions.

Frequently Asked Questions

What is the UGV Beast?
The UGV Beast is a Research robot made by Waveshare. Waveshare's UGV Beast is an open-source off-road tracked AI robot platform for Raspberry Pi 4B or Raspberry Pi 5 developers. The official store page and wiki describe a dual-controller architecture: the Raspberry Pi handles higher-level AI vision, WebRTC browser control, JupyterLab tutorials, and strategy code while an ESP32 sub-controller handles motor PID, IMU data, pan-tilt/LED control, OLED status, battery sensing, and ESP-NOW communication. The tracked aluminum chassis adds independent suspension, zero-radius turning, optional 2-DOF pan-tilt with a 5MP 160-degree camera, OpenCV/MediaPipe demos for face, object, color, gesture, and line tracking, and hardware expansion for LiDAR, 4G/5G, audio, and GPIO peripherals. It is a maker and research platform rather than a consumer home-helper robot, but it clears ui44's bar through its open software stack, dual-controller design, computer-vision demos, and rugged mobile-robot hardware.
How much does the UGV Beast cost?
The UGV Beast is listed at USD $265. Official Waveshare store page lists UGV Beast kit variants from US$264.99 to US$501.99 depending on Raspberry Pi 4B/5, pan-tilt, and accessory configuration; 18650 batteries are not included.
Is the UGV Beast available to buy?
The UGV Beast is listed as Available, indicating an ordering listing. The label does not confirm current stock, regional access, or shipping dates. Check Waveshare's current ordering terms and the recorded sales notes for details.
What sensors are reported for the UGV Beast?
The profile lists the sensor descriptions below. These entries do not establish physical sensor counts, sensor fusion, redundancy, or performance. Optional 5MP 160-degree camera on 2-DOF pan-tilt, ICM20948 9-axis IMU, Motor encoders for closed-loop speed control, INA219 battery-voltage monitoring, Dual-track microphone and speaker audio board, Expansion space/interfaces for D500 or STL-27L LiDAR See the sensor information section for details.
What AI does the UGV Beast use?
How does the UGV Beast compare to the SpikerBot?
The UGV Beast and SpikerBot are both research robots, but they differ in key specifications, pricing, and manufacturer approach. Use the side-by-side comparison tool to see detailed differences in specs, sensors, and capabilities. You can also browse other similar robots.
What platforms or ecosystem relationships are listed for the UGV Beast?
These are the platforms, communities, or ecosystem relationships listed in the profile. A listed name or protocol alone does not confirm home-device interoperability or automation support. Raspberry Pi 4B, Raspberry Pi 5, Debian Bookworm, ROS2 Humble, Python, Flask, WebRTC, OpenCV, MediaPipe, JupyterLab, ESP-NOW
How current is the UGV Beast data on ui44?
The UGV Beast record has a last-checked date of 2026-07-03. Consult the model description, source links, and attribution notes for the basis of individual claims. This date does not mean every claim is manufacturer-confirmed or independently tested. If you notice outdated information, please let us know.

Data Integrity

The UGV Beast record brings together the listed specifications and attributed claims. Consult the model description and source notes to distinguish manufacturer announcements, reported information, and unknowns. A source link or review date does not establish independent testing or manufacturer confirmation of every claim. Record last checked: 2026-07-03. Official source: Waveshare official source. If you find outdated or incorrect information, please let us know — accuracy is our top priority.

Explore More on ui44

Explore more research robots

See how the UGV Beast stacks up — compare specs, browse the research category, or search the full database.