Commercial model
See pricing details
Official pricing, ordering terms, and shipping availability were not published on Lumos Robotics' product page. Third-party directory prices conflict and are not used.

Height
160 cm
Weight
57 kg
Speed
2 m/s
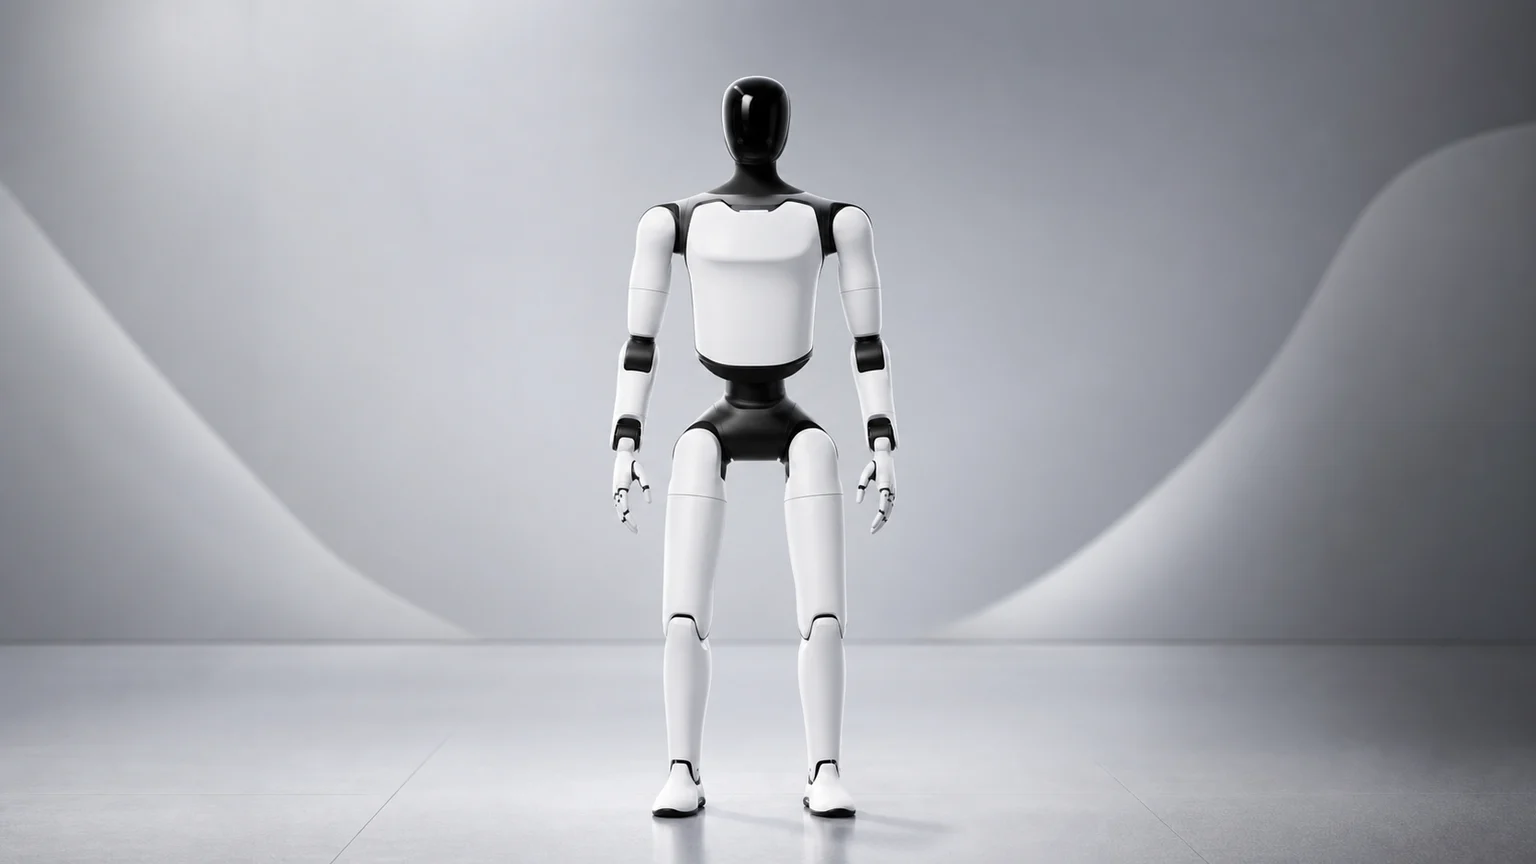
LUS2 is a full-size humanoid robot platform from Lumos Robotics for research, education, and commercial applications. Lumos' official product page lists a 160 cm, 57 kg robot with 28 total degrees of freedom, a 2 m/s maximum speed, 360 N·m maximum joint torque, Intel RealSense D435i vision, finger and palm tactile sensors, an IMU, 360° LiDAR, NVIDIA Orin AGX compute rated at 275 TOPS, a dedicated real-time control processor, Wi-Fi, EtherCAT, and a Linux-based operating system. The company positions LUS2 as a modular, open-architecture platform for object manipulation, navigation, human-robot interaction, industrial automation, service, entertainment, and university or lab development work. Public price, exact launch date, ship timing, charging time, runtime, and payload have not been officially disclosed.
Listed price
See pricing details
Official pricing, ordering terms, and shipping availability were not published on Lumos Robotics' product page. Third-party directory prices conflict and are not used.
Release window
TBD
Current status
Active
Lumos Robotics
Last verified
May 17, 2026
Share this robot
Open a plain share composer on X or Bluesky for this robot profile.
Technical overview
A fast read on the mechanical profile, sensing package, and listed platform details for LUS2.
Height
160 cm
Weight
57 kg
Battery Life
Runtime not publicly disclosed (10 Ah, 54 V battery)
Charging Time
Not publicly disclosed
Max Speed
2 m/s
Operational profile
Capabilities
9
Connectivity
2
Key capabilities
Listed platforms & ecosystem
Explore further
Benchmark set
Shortcuts to the closest alternatives in the current ui44 set.

Humanoid
LUMOS NIX
Lumos Robotics
See pricing details
Humanoid
A3 Ultra
AGIBOT
See pricing details

Humanoid
Kengo
Galaxea Dynamics
$999,999

Humanoid
Dyno
VinDynamics
See pricing details
The LUS2 is a Humanoid robot built by Lumos Robotics. LUS2 is a full-size humanoid robot platform from Lumos Robotics for research, education, and commercial applications. Lumos' official product page lists a 160 cm, 57 kg robot with 28 total degrees of freedom, a 2 m/s maximum speed, 360 N·m maximum joint torque, Intel RealSense D435i vision, finger and palm tactile sensors, an IMU, 360° LiDAR, NVIDIA Orin AGX compute rated at 275 TOPS, a dedicated real-time control processor, Wi-Fi, EtherCAT, and a Linux-based operating system. The company positions LUS2 as a modular, open-architecture platform for object manipulation, navigation, human-robot interaction, industrial automation, service, entertainment, and university or lab development work. Public price, exact launch date, ship timing, charging time, runtime, and payload have not been officially disclosed.
Official pricing, ordering terms, and shipping availability were not published on Lumos Robotics' product page. Third-party directory prices conflict and are not used. See all Lumos Robotics robots on the Lumos Robotics page.
Detailed specifications for the LUS2
Height
160 cmThe listed height is 160 cm. Height alone does not establish working reach or clearance under furniture; check the documented operating configuration and required space.
Weight
57 kgThe listed weight is 57 kg. Weight alone does not establish locomotion, stability or safety around people. Check handling requirements and the model’s documented operating limits.
Battery Life
Runtime not publicly disclosed (10 Ah, 54 V battery)This is the recorded runtime entry. Test conditions and independent verification are not established by this field. Confirm workload, operating mode and environmental conditions before comparing runtimes.
Maximum Speed
2 m/sThe recorded maximum-speed entry is 2 m/s. It does not establish sustained travel speed, terrain handling, or safe speed around people. Check the source's gait, operating mode, surface and load conditions before planning movement through a shared space.
Read this recorded AI entry alongside the model description and source notes for announcement or deployment context. A platform name alone does not establish implemented features, autonomy, or performance.
The profile lists the sensor descriptions below. These entries do not establish physical sensor counts, sensor fusion, redundancy, or performance.
Consult the linked profile sources for hardware configuration and tested behavior. A technology label alone does not verify an operating capability.
Explore sensor technologies: components glossary · full components directory
The Humanoid category includes different mobility configurations. Check the specific model’s documented locomotion, doorway clearances and operating surfaces. Category membership alone does not establish stair capability or suitability for an unmodified workspace.
The LUS2 record lists 9 capabilities. Keep any announcement or demonstration qualifiers attached to these entries; the count alone does not establish practical performance.
These are the capabilities listed in the profile. Hardware configuration and demonstrated performance should be checked against the linked sources.
These are the platforms, communities, or ecosystem relationships listed in the profile. A listed name or protocol alone does not confirm home-device interoperability or automation support.
9
Capabilities
AI
NVIDIA Orin AGX compute…
The LUS2 profile lists the following communication and voice-system descriptions.
The LUS2 by Lumos Robotics has the following technology descriptions in its profile. The physical platform features a height of 160 cm, a weight of 57 kg, a top speed of 2 m/s, providing the foundation on which this technology stack operates.
The profile lists Intel RealSense D435i vision system, Finger and palm tactile sensors, IMU, 360° LiDAR. Hardware quantities, integration, and tested behavior require separate source evidence.
Humanoid robots are typically targeted at enterprise customers, research institutions, and forward-thinking businesses looking to automate tasks that require human-like form and dexterity. While some models are approaching consumer pricing, the majority remain in the commercial and industrial space.
When evaluating a humanoid robot, payload capacity, degrees of freedom, and manipulation dexterity are critical factors. Battery life and charging time determine operational uptime. The AI platform determines how well the robot can adapt to new tasks and environments. Consider whether the robot needs to work alongside humans (requiring safety certifications) or will operate independently.
Listed pricing
The LUS2 is listed as Active. This status alone does not confirm public purchase availability or operational reliability. Contact Lumos Robotics for current access options and any purchase or participation requirements.
Recorded features and considerations to assess
The LUS2 record lists 9 capabilities. Review their qualifiers and supporting evidence for the tasks you need. The number of entries does not establish workflow coverage, reliability, or the ability to replace other robots.
The speed entry is 2 m/s. Preserve its gait, mode, and comparison qualifiers when comparing models. This figure alone does not establish agility, response time, terrain handling, or safe speed around people.
At 57 kg, the LUS2 is a substantial piece of equipment. Check documented floor-load limits, transport and handling requirements, and operating precautions. Weight alone does not establish stability, robustness or safety around people.
Official pricing, ordering terms, and shipping availability were not published on Lumos Robotics' product page. Third-party directory prices conflict and are not used.
Note: This strengths and trade-offs assessment is based on the LUS2's documented specifications as tracked in the ui44 database. Real-world performance depends on deployment conditions, firmware maturity, and environmental factors. For the most current information, check the Lumos Robotics manufacturer page or visit the official source. Use the comparison tool to evaluate these trade-offs against competing robots in the same category.
Understanding the engineering behind this category
Humanoid robots represent one of the most technically ambitious categories in robotics. Building a machine that walks, balances, manipulates objects, and interacts naturally with humans requires breakthroughs across multiple engineering disciplines simultaneously. Understanding the technology behind humanoid robots helps buyers and enthusiasts appreciate both the capabilities and limitations of current systems.
Humanoid robots navigate using a combination of visual SLAM (Simultaneous Localization and Mapping), depth sensing, and inertial measurement. Unlike wheeled robots that simply avoid obstacles, humanoids must plan footstep placement, maintain dynamic balance on uneven surfaces, and anticipate terrain changes. Advanced systems use predictive models to plan several steps ahead, similar to how humans unconsciously adjust their gait when approaching stairs or rough ground. The computational requirements for real-time bipedal navigation are substantial, often requiring dedicated motion-planning processors separate from the main AI system.
Artificial intelligence in humanoid robots serves multiple roles: high-level task planning (understanding what needs to be done), perception (recognizing objects, people, and environments), manipulation planning (figuring out how to grasp and move objects), and social interaction (understanding speech, gestures, and context). Modern humanoids increasingly use large language models and vision-language models for task understanding, allowing them to interpret natural language instructions and generalize to new tasks without explicit programming for each scenario.
The sensor suite in a humanoid robot must provide comprehensive environmental awareness while maintaining real-time processing speeds. Sensor fusion algorithms combine data from cameras, LiDAR, depth sensors, force/torque sensors, and IMUs to create a unified model of the robot's surroundings. This multi-modal perception is critical because no single sensor type works perfectly in all conditions — cameras struggle in darkness, LiDAR cannot distinguish materials, and touch sensors only detect what the robot physically contacts. By combining these inputs, the robot achieves more robust and reliable perception than any individual sensor could provide.
Battery technology is one of the primary limiting factors for humanoid robots. Bipedal locomotion is inherently energy-intensive — maintaining balance requires constant motor activity even when standing still. Current lithium-ion battery packs typically provide two to four hours of active operation, with charging times that can match or exceed operational time. Research into more efficient actuators, energy-harvesting techniques, and advanced battery chemistries aims to extend operational windows. Some commercial deployments address this limitation through battery-swap systems or scheduled charging rotations.
Safety in humanoid robotics is paramount because these robots operate in close proximity to humans. Design approaches include compliant actuators that absorb impact forces, real-time collision prediction systems, force-limited joints that automatically reduce power when unexpected contact occurs, and emergency stop mechanisms accessible to nearby humans. International safety standards like ISO 13482 for personal care robots provide frameworks for evaluating safety, but the field is still developing standards specific to general-purpose humanoid systems. Buyers should inquire about safety testing, certifications, and the robot's behavior in failure modes.
The humanoid robotics field is advancing rapidly on multiple fronts. Improvements in foundation models are enabling more generalizable intelligence. New actuator designs are making robots lighter and more efficient. Manufacturing scale is driving down costs. Over the next several years, expect humanoid robots to transition from controlled industrial environments to more varied commercial and eventually residential settings. The convergence of better AI, cheaper hardware, and proven deployment experience will accelerate adoption across industries.
These are category-level technology examples; they do not establish the capabilities of the LUS2. For its recorded hardware details, see the sensor analysis and connectivity sections above. Check model-specific documentation from Lumos Robotics for supported behavior, or use the components glossary to look up terminology.
How this robot compares in the humanoid landscape
Official pricing, ordering terms, and shipping availability were not published on Lumos Robotics' product page. Third-party directory prices conflict and are not used.
The LUS2 is listed as Active. This status alone does not confirm public purchase availability or operational reliability. Contact Lumos Robotics for current access options and any purchase or participation requirements.
Side-by-side specs, capability overlap analysis, and key differentiators.
For the full picture of Lumos Robotics's portfolio and market strategy, visit the Lumos Robotics manufacturer page.
What the public profile tells you, and what still needs direct vendor confirmation
From a buying and rollout perspective, the LUS2 should be read as a humanoid platform aimed at human-scale workplaces and pilot automation programs. ui44 currently tracks 9 capability signals and a last verification date of 2026-05-17. That mix gives buyers a useful first-pass picture, but it is still only the public layer of due diligence, especially when procurement, uptime, and support commitments are decided directly with Lumos Robotics.
Commercial model
See pricing details
Official pricing, ordering terms, and shipping availability were not published on Lumos Robotics' product page. Third-party directory prices conflict and are not used.
Integration posture
2 connectivity options
The profile lists Wi-Fi, EtherCAT. These labels do not establish APIs, fleet-management features, or workflow integration. These are the platforms, communities, or ecosystem relationships listed in the profile. A listed name or protocol alone does not confirm home-device interoperability or automation support.
Spec disclosure
3/7 core specs public
ui44 currently has 3 of 7 core physical and operating specs filled in for this model, leaving 4 gaps that matter for deployment planning. Missing runtime, charge, speed, or payload details can materially change staffing and site-readiness assumptions.
The current profile is useful for scouting, but it still leaves meaningful operational unknowns. If this robot is heading toward a pilot or purchase discussion, the next step should be a structured vendor Q&A that fills the remaining runtime, charging, payload, safety, or integration blanks before anyone builds ROI assumptions around it.
If you want a faster apples-to-apples read, compare the LUS2 against nearby alternatives in ui44's compare view, then cross-check the underlying AI, sensor, and subsystem terms in the components glossary. For manufacturer-level context, the Lumos Robotics profile helps anchor this robot inside the wider product lineup.
Practical guide from day one through years of ownership
Setting up a humanoid robot is substantially more involved than plug-and-play consumer devices. Expect a professional installation or guided setup process that includes physical unpacking and assembly (if shipped disassembled), initial calibration of joints and sensors, environment mapping and safety zone definition, network and cloud service configuration, and application-specific programming or task teaching. Plan for several hours to a full day of setup time, and budget for potential integration consulting if the robot needs to connect with existing systems. The manufacturer or a certified integrator should provide training on safe operation, emergency procedures, and basic troubleshooting.
Humanoid robots require regular maintenance to ensure safe and reliable operation. Monthly maintenance typically includes visual inspection of joints and actuators for wear, sensor cleaning (especially cameras and LiDAR), firmware and software updates, battery health checks, and calibration verification. Quarterly maintenance may include more thorough mechanical inspection, lubrication of moving parts, and performance benchmarking to detect gradual degradation. Keep a maintenance log and follow the manufacturer's recommended schedule precisely — humanoid robots are complex systems where small issues can cascade if not addressed promptly.
Humanoid robot software is evolving rapidly, and regular updates can significantly improve performance, add new capabilities, and patch security vulnerabilities. Most manufacturers provide over-the-air updates, but enterprise deployments may require staging and testing updates before rolling them out. Evaluate the manufacturer's update track record — frequent, well-documented updates indicate active development and long-term commitment. Be aware that major software updates may require recalibration or retraining of custom behaviors.
To maximize the useful life of a humanoid robot, avoid operating beyond specified payload limits, maintain a controlled environment (temperature, humidity), keep sensors clean and unobstructed, and address any unusual sounds or behaviors promptly. Battery longevity is improved by avoiding deep discharges and extreme temperatures during charging. Investing in a service contract with the manufacturer or a certified partner provides access to replacement parts and expertise that can extend the robot's productive life significantly beyond the standard warranty period.
Find product and source links on the Lumos Robotics page on ui44 or open Lumos Robotics's official source. Use model-specific manufacturer documentation for setup, cleaning, and service instructions.
The LUS2 record brings together the listed specifications and attributed claims. Consult the model description and source notes to distinguish manufacturer announcements, reported information, and unknowns. A source link or review date does not establish independent testing or manufacturer confirmation of every claim. Record last checked: 2026-05-17. Official source: Lumos Robotics official source. If you find outdated or incorrect information, please let us know — accuracy is our top priority.
See how the LUS2 stacks up — compare specs, browse the humanoid category, or search the full database.