Rover X1

Height

Not separately disclosed; official size table lists 820 x 480 x 180 mm

Weight

~15 kg

Battery

Approximately 90 minutes with standard battery; approximately 180 minutes with high-capacity battery

Speed

Standard version: 1.25 m/s walking, 1.8 m/s running; wheel-foot version: up to 2.5 m/s, or 3 m/s in wheel-only mode

Payload

Official specs list 3 kg for both point-foot and wheel-foot versions; product imagery also markets 3-7 kg high-payload carrying ability

Quadruped Pre-order

Rover X1

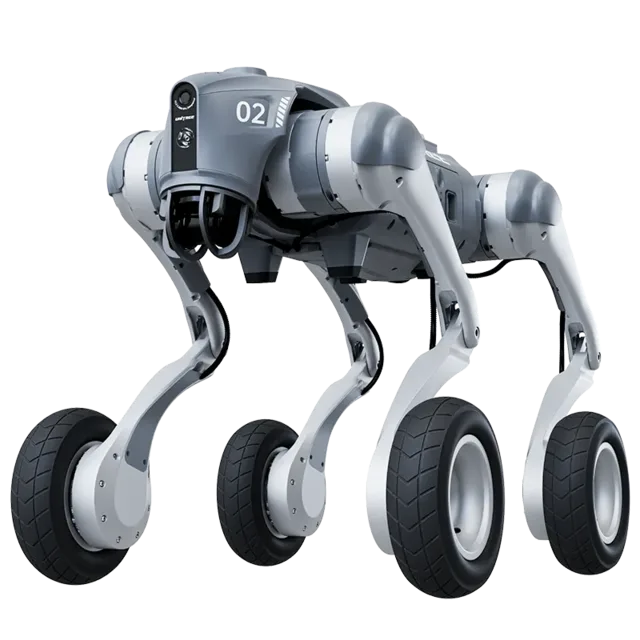
Rover X1 is DOBOT's INFFNI-branded consumer quadruped robot dog for home, outdoor carrying, follow filming, and companionship. DOBOT announced it as a smart quadruped robot designed for every home for CES 2026, while the INFFNI preorder page lists variants for US and EU buyers. Official materials describe all-terrain mobility, intelligent subject tracking, dual-vision smart perception, app/gesture/voice/remote control, small-item transport, and expressive companion behaviors; independent TechNode coverage corroborates the household positioning, hybrid wheel-leg option, item carrying, filming, patrol, coding-education, and companion use cases.

Listed price

$2,199

Official INFFNI preorder page lists Rover X1 variants from $2,199 to $2,749 USD, with Europe/North America preorder stock due in mid-June 2026 and shipment sequentially after warehouse arrival. TechNode separately reported a RMB 7,499 China launch price in November 2025.

Release window

Jan 1, 2026

Current status

Pre-order

DOBOT

Last verified

Jun 9, 2026

Share this robot

Open a plain share composer on X or Bluesky for this robot profile.

Technical overview

Core specifications and system stack

A fast read on the mechanical profile, sensing package, and listed platform details for Rover X1.

Technical Specifications

Height

Not separately disclosed; official size table lists 820 x 480 x 180 mm

Weight

~15 kg

Dimensions

820 x 480 x 180 mm

Battery Life

Approximately 90 minutes with standard battery; approximately 180 minutes with high-capacity battery

Charging Time

Not officially disclosed

Max Speed

Standard version: 1.25 m/s walking, 1.8 m/s running; wheel-foot version: up to 2.5 m/s, or 3 m/s in wheel-only mode

Payload

Official specs list 3 kg for both point-foot and wheel-foot versions; product imagery also markets 3-7 kg high-payload carrying ability

Operational profile

How this robot is configured

Capabilities

12

Connectivity

2

Key capabilities

Quadruped MobilityWheel-foot Mobility OptionIntelligent Subject TrackingFollow ModeSmall-item TransportOutdoor Filming SupportReal-time App Image TransmissionGesture Control

Listed platforms & ecosystem

iOS 10.0+Android 9.0+

About the Rover X1

2Protocols12CapabilitiesUSD $2,199Listed Price

The Rover X1 is a Quadruped robot built by DOBOT. Rover X1 is DOBOT's INFFNI-branded consumer quadruped robot dog for home, outdoor carrying, follow filming, and companionship. DOBOT announced it as a smart quadruped robot designed for every home for CES 2026, while the INFFNI preorder page lists variants for US and EU buyers. Official materials describe all-terrain mobility, intelligent subject tracking, dual-vision smart perception, app/gesture/voice/remote control, small-item transport, and expressive companion behaviors; independent TechNode coverage corroborates the household positioning, hybrid wheel-leg option, item carrying, filming, patrol, coding-education, and companion use cases.

The Rover X1 is listed at USD $2,199. Official INFFNI preorder page lists Rover X1 variants from $2,199 to $2,749 USD, with Europe/North America preorder stock due in mid-June 2026 and shipment sequentially after warehouse arrival. TechNode separately reported a RMB 7,499 China launch price in November 2025. See all DOBOT robots on the DOBOT page.

Spec Breakdown

Detailed specifications for the Rover X1

Height

Not separately disclosed; official size table lists 820 x 480 x 180 mm

The listed height is Not separately disclosed; official size table lists 820 x 480 x 180 mm. Height alone does not establish working reach or clearance under furniture; check the documented operating configuration and required space.

Weight

Approximately 15 kg complete device set

The listed weight is Approximately 15 kg complete device set. Weight alone does not establish locomotion, stability or safety around people. Check handling requirements and the model’s documented operating limits.

Dimensions

820 x 480 x 180 mm

The overall dimensions of 820 x 480 x 180 mm are a recorded size entry. Check which axes and configuration it covers: a height-only entry does not establish width, depth or passage fit. Planning clearance also requires the operating envelope, turning space, attachments and documented margins.

Battery Life

Approximately 90 minutes with standard battery; approximately 180 minutes with high-capacity battery

This is the recorded runtime entry. Test conditions and independent verification are not established by this field. Confirm workload, operating mode and environmental conditions before comparing runtimes.

Maximum Speed

Standard version: 1.25 m/s walking, 1.8 m/s running; wheel-foot version: up to 2.5 m/s, or 3 m/s in wheel-only mode

The recorded maximum-speed entry is Standard version: 1.25 m/s walking, 1.8 m/s running; wheel-foot version: up to 2.5 m/s, or 3 m/s in wheel-only mode. It does not establish sustained travel speed, terrain handling, or safe speed around people. Check the source's gait, operating mode, surface and load conditions before planning movement through a shared space.

Payload Capacity

Official specs list 3 kg for both point-foot and wheel-foot versions; product imagery also markets 3-7 kg high-payload carrying ability

The recorded payload entry is Official specs list 3 kg for both point-foot and wheel-foot versions; product imagery also markets 3-7 kg high-payload carrying ability. A load figure alone does not establish which objects the robot can grasp, lift or carry. Confirm whether the limit applies to one arm, two arms or a mounted load, and check reach, posture and motion conditions in model-specific documentation.

Read this recorded AI entry alongside the model description and source notes for announcement or deployment context. A platform name alone does not establish implemented features, autonomy, or performance.

Rover X1 Sensor Suite

The profile lists the sensor descriptions below. These entries do not establish physical sensor counts, sensor fusion, redundancy, or performance.

Consult the linked profile sources for hardware configuration and tested behavior. A technology label alone does not verify an operating capability.

Explore sensor technologies: components glossary · full components directory

Rover X1 Use Cases & Applications

Four-legged robots excel in environments where wheeled robots struggle — stairs, rough terrain, construction sites, and industrial facilities. Their biological-inspired locomotion provides stability and adaptability that makes them versatile platforms for a wide range of applications.

Recorded Capabilities

The Rover X1 record lists 12 capabilities. Keep any announcement or demonstration qualifiers attached to these entries; the count alone does not establish practical performance.

Quadruped Mobility
Wheel-foot Mobility Option
Intelligent Subject Tracking
Follow Mode
Small-item Transport
Outdoor Filming Support
Real-time App Image Transmission
Gesture Control
Voice Control
Remote Control
Expressive Companion Behaviors
Home Patrol and Coding-education Use Cases

These are the capabilities listed in the profile. Hardware configuration and demonstrated performance should be checked against the linked sources.

Listed Platforms & Ecosystem

These are the platforms, communities, or ecosystem relationships listed in the profile. A listed name or protocol alone does not confirm home-device interoperability or automation support.

iOS 10.0+ Android 9.0+

Rover X1 Capabilities

12

Capabilities

AI

INFFNI/DOBOT describes…

Quadruped Mobility
Wheel-foot Mobility Option
Intelligent Subject Tracking
Follow Mode
Small-item Transport
Outdoor Filming Support
Real-time App Image Transmission
Gesture Control
Voice Control
Remote Control
Expressive Companion Behaviors
Home Patrol and Coding-education Use Cases

Listed Connectivity & Voice Systems

The Rover X1 profile lists the following communication and voice-system descriptions.

Network & Communication Details

Listed network interfaces do not by themselves identify supported services, integrations, or device-control functions.

Listed Voice Systems

Supported commands and device controls require product-specific documentation.

Rover X1 Technology Stack Overview

The Rover X1 by DOBOT has the following technology descriptions in its profile. The physical platform features a height of Not separately disclosed; official size table lists 820 x 480 x 180 mm, a weight of Approximately 15 kg complete device set, a top speed of Standard version: 1.25 m/s walking, 1.8 m/s running; wheel-foot version: up to 2.5 m/s, or 3 m/s in wheel-only mode, providing the foundation on which this technology stack operates.

Reported sensing

The profile lists Dual vision and smart perception, Dual-vision tracking system. Hardware quantities, integration, and tested behavior require separate source evidence.

Listed connectivity

The connectivity descriptions listed for the Rover X1 are iOS/Android mobile app with Bluetooth pairing, Remote controller. Specific services and device interoperability require separate documentation.

Voice — Built-in voice commands within 1-2 m

The profile lists these voice systems: Built-in voice commands within 1-2 m. This listing does not establish control of other devices or support for particular automation routines.

Who Should Consider the Rover X1?

Target Audience

Quadruped robots are primarily purchased by industrial and enterprise customers for inspection, patrol, and data collection in environments too dangerous or tedious for humans. Some companion-oriented quadrupeds target tech-savvy consumers.

Key Considerations

Terrain adaptability, payload capacity for sensor payloads, runtime per charge, IP rating for outdoor/industrial use, and autonomous navigation in unstructured environments are key factors. For industrial use, consider integration with existing asset management and inspection workflows.

Listed pricing

The Rover X1 is listed at USD $2,199. Official INFFNI preorder page lists Rover X1 variants from $2,199 to $2,749 USD, with Europe/North America preorder stock due in mid-June 2026 and shipment sequentially after warehouse arrival. TechNode separately reported a RMB 7,499 China launch price in November 2025.

Availability

Pre-order

The Rover X1 is listed for pre-order, indicating a reservation listing. The label alone does not establish engineering completion or guarantee a delivery queue position. Check DOBOT's reservation terms, regional availability, and estimated delivery dates.

Rover X1: Strengths & Trade-offs

Recorded features and considerations to assess

Recorded features to assess for the Rover X1

Recorded capability range

The Rover X1 record lists 12 capabilities. Review their qualifiers and supporting evidence for the tasks you need. The number of entries does not establish workflow coverage, reliability, or the ability to replace other robots.

What to consider carefully

Battery runtime to assess

The battery-life entry is Approximately 90 minutes with standard battery; approximately 180 minutes with high-capacity battery. Check the operating mode and source conditions against your intended session. This entry alone does not establish a charging schedule or a need for additional units.

Listed Pre-order

The Rover X1 is listed for pre-order, indicating a reservation listing. The label alone does not establish engineering completion or guarantee a delivery queue position. Check DOBOT's reservation terms, regional availability, and estimated delivery dates.

Note: This strengths and trade-offs assessment is based on the Rover X1's documented specifications as tracked in the ui44 database. Real-world performance depends on deployment conditions, firmware maturity, and environmental factors. For the most current information, check the DOBOT manufacturer page or visit the official source. Use the comparison tool to evaluate these trade-offs against competing robots in the same category.

How Quadruped Robot Technology Works

Understanding the engineering behind this category

Four-legged robots represent a biomimetic approach to mobility — taking inspiration from nature's most versatile terrestrial locomotion strategy. Unlike wheeled or tracked robots, quadrupeds can navigate stairs, step over obstacles, traverse rough terrain, and recover from stumbles. The engineering behind these machines combines advanced control theory, real-time computation, and rugged mechanical design into platforms that go where other robots simply cannot.

Navigation & Mobility

Quadruped navigation combines classical SLAM with proprioceptive terrain sensing. The robot builds environment maps using LiDAR and cameras while simultaneously using force sensors in its feet and joint torque measurements to understand ground conditions beneath each footstep. This dual approach — seeing ahead while feeling underfoot — enables navigation through environments that would confuse purely vision-based systems, like muddy terrain or surfaces covered in snow. Path planning for legged robots is more complex than for wheeled platforms because the planner must consider foothold locations, body clearance, and dynamic stability at every step.

The Role of AI

AI in quadruped robots increasingly relies on learned locomotion policies trained in simulation and transferred to real hardware. Rather than hand-coding gait controllers for every terrain type, modern systems use reinforcement learning to develop robust walking behaviors that generalize across surfaces. This sim-to-real approach has dramatically improved quadruped agility and robustness. Higher-level AI handles mission planning, autonomous inspection routines, anomaly detection, and integration with enterprise software systems for industrial applications.

Sensor Fusion & Perception

Quadruped robots carry sophisticated sensor payloads combining environmental perception with proprioceptive awareness. Outward-facing sensors (LiDAR, cameras, depth sensors) map the environment and identify obstacles. Inward-facing sensors (joint encoders, IMUs, force/torque sensors) monitor the robot's own state — its balance, footing, and body orientation. The fusion of external and internal sensing is uniquely important for legged robots because stable locomotion requires constant feedback about both where the robot is going and how its body is responding to each step. Payload-mounted inspection sensors (thermal cameras, gas detectors, acoustic sensors) add application-specific perception on top of the mobility platform.

Power & Battery Management

Legged locomotion is energy-intensive, and battery life is a critical constraint for quadruped robots. Most commercial quadrupeds offer one to two hours of active operation per charge. Power consumption varies significantly with gait speed, terrain difficulty, and payload weight. Battery-swap systems are common in industrial deployments, allowing continuous operation through multiple battery packs. Some facilities install automatic charging stations where the robot can dock and recharge between patrol routes. Efficient gait selection — using the least energy-consuming walking pattern appropriate for current terrain — is an active optimization area.

Safety by Design

Quadruped robots operating in industrial and public environments must handle safety across multiple dimensions. Physical safety features include compliant leg designs that absorb unexpected impacts, emergency stop buttons, and speed-limiting zones around detected humans. Autonomous safety behaviors include automatic sit-down when battery reaches critical levels, return-to-base when communication is lost, and avoidance of detected hazards. For outdoor operation, IP ratings (typically IP54 or higher) ensure resistance to dust and water. Operational geofencing ensures the robot stays within approved areas.

What's Next for Quadruped Robots

Quadruped robotics is moving toward greater autonomy, longer endurance, and expanded manipulation capability. The addition of robotic arms to quadruped platforms is creating mobile manipulation systems that can not only inspect but also interact with the environment — turning valves, pressing buttons, or collecting samples. Improved batteries and more efficient actuators are extending operational windows. Fleet coordination of multiple quadrupeds for large-area coverage is becoming practical. As costs decrease, quadruped robots are expanding from premium industrial inspection tools into more accessible commercial and even consumer applications.

These are category-level technology examples; they do not establish the capabilities of the Rover X1. For its recorded hardware details, see the sensor analysis and connectivity sections above. Check model-specific documentation from DOBOT for supported behavior, or use the components glossary to look up terminology.

Rover X1 in the Quadruped Market

How this robot compares in the quadruped landscape

The Rover X1 is listed at USD $2,199. Official INFFNI preorder page lists Rover X1 variants from $2,199 to $2,749 USD, with Europe/North America preorder stock due in mid-June 2026 and shipment sequentially after warehouse arrival. TechNode separately reported a RMB 7,499 China launch price in November 2025.

The Rover X1 is listed for pre-order, indicating a reservation listing. The label alone does not establish engineering completion or guarantee a delivery queue position. Check DOBOT's reservation terms, regional availability, and estimated delivery dates.

Head-to-Head Comparisons

Side-by-side specs, capability overlap analysis, and key differentiators.

For the full picture of DOBOT's portfolio and market strategy, visit the DOBOT manufacturer page.

Deployment Readiness and Procurement Signals for Rover X1

What the public profile tells you, and what still needs direct vendor confirmation

From a buying and rollout perspective, the Rover X1 should be read as a quadruped platform aimed at inspection routes and terrain that challenge wheeled platforms. ui44 currently tracks 12 capability signals and a last verification date of 2026-06-09. That mix gives buyers a useful first-pass picture, but it is still only the public layer of due diligence, especially when procurement, uptime, and support commitments are decided directly with DOBOT.

Commercial model

USD $2,199 list price

The Rover X1 is listed at USD $2,199. Official INFFNI preorder page lists Rover X1 variants from $2,199 to $2,749 USD, with Europe/North America preorder stock due in mid-June 2026 and shipment sequentially after warehouse arrival. TechNode separately reported a RMB 7,499 China launch price in November 2025.

Integration posture

2 connectivity options

The profile lists iOS/Android mobile app with Bluetooth pairing, Remote controller. These labels do not establish APIs, fleet-management features, or workflow integration. These are the platforms, communities, or ecosystem relationships listed in the profile. A listed name or protocol alone does not confirm home-device interoperability or automation support.

Spec disclosure

6/7 core specs public

ui44 currently has 6 of 7 core physical and operating specs filled in for this model, leaving 1 gap that matter for deployment planning. Missing runtime, charge, speed, or payload details can materially change staffing and site-readiness assumptions.

The current profile is detailed enough to support early comparison work, shortlist creation, and cross-checking against other quadruped robots. It is still worth validating the final deployment package, because integration services, support coverage, software entitlements, and site-preparation requirements often sit outside the raw hardware spec sheet.

If you want a faster apples-to-apples read, compare the Rover X1 against nearby alternatives in ui44's compare view, then cross-check the underlying AI, sensor, and subsystem terms in the components glossary. For manufacturer-level context, the DOBOT profile helps anchor this robot inside the wider product lineup.

Before you sign off on a pilot, confirm these points

  • Confirm how the charging workflow works in practice, including charger count, swap options, and expected downtime.
  • Check what safety, electrical, or deployment certifications exist for the region and task you care about.

Owning the Rover X1: Setup, Maintenance & Tips

Practical guide from day one through years of ownership

Initial Setup

Quadruped robot setup typically involves professional installation or detailed guided procedures. Initial steps include unpacking and physical inspection, charging the battery fully before first use, installing any payload accessories (sensors, cameras, manipulators), connecting to the control network, running joint calibration and self-test routines, and mapping the initial operating environment. Industrial deployments may require integration with facility networks, security systems, and asset management platforms. Plan for a multi-day setup process for enterprise installations, including operator training and safety protocol establishment.

Ongoing Maintenance

Quadruped robots require more frequent maintenance than wheeled platforms due to the mechanical complexity of their legs. Weekly checks should include joint inspection for unusual sounds or play, foot pad condition assessment, sensor cleaning, and battery health verification. Monthly maintenance includes more thorough mechanical inspection, firmware updates, and locomotion performance benchmarking. Legs and joints are the primary wear points — monitor for vibration changes that might indicate bearing wear or actuator degradation. Keep a detailed maintenance log, as patterns in the data can predict component failures before they cause operational disruption.

Software Updates & Long-Term Support

Quadruped robot software updates can significantly improve locomotion performance, autonomous navigation capability, and mission execution efficiency. Gait improvements based on real-world deployment data can make the robot faster, more stable, and more energy-efficient. Security patches are particularly important for robots operating in sensitive industrial or commercial environments. Coordinate updates with your deployment schedule to avoid disruption, and test updates in a controlled area before returning the robot to active duty.

Maximizing Longevity

Maximizing the service life of a quadruped robot requires attention to both mechanical and environmental factors. Operate within specified payload limits to avoid accelerated joint wear. Use appropriate gaits for the terrain — running on flat floors when a walk would suffice wastes energy and increases mechanical stress. Keep the robot's IP-rated seals in good condition for outdoor operation. Battery care is critical: follow the manufacturer's charging guidelines, avoid deep discharges, and replace batteries when capacity drops below 80% of original. A service contract with the manufacturer ensures access to replacement parts and expert maintenance that can keep the robot operational for many years.

Find product and source links on the DOBOT page on ui44 or open DOBOT's official source. Use model-specific manufacturer documentation for setup, cleaning, and service instructions.

Frequently Asked Questions

What is the Rover X1?
The Rover X1 is a Quadruped robot made by DOBOT. Rover X1 is DOBOT's INFFNI-branded consumer quadruped robot dog for home, outdoor carrying, follow filming, and companionship. DOBOT announced it as a smart quadruped robot designed for every home for CES 2026, while the INFFNI preorder page lists variants for US and EU buyers. Official materials describe all-terrain mobility, intelligent subject tracking, dual-vision smart perception, app/gesture/voice/remote control, small-item transport, and expressive companion behaviors; independent TechNode coverage corroborates the household positioning, hybrid wheel-leg option, item carrying, filming, patrol, coding-education, and companion use cases.
How much does the Rover X1 cost?
The Rover X1 is listed at USD $2,199. Official INFFNI preorder page lists Rover X1 variants from $2,199 to $2,749 USD, with Europe/North America preorder stock due in mid-June 2026 and shipment sequentially after warehouse arrival. TechNode separately reported a RMB 7,499 China launch price in November 2025.
Is the Rover X1 available to buy?
The Rover X1 is listed for pre-order, indicating a reservation listing. The label alone does not establish engineering completion or guarantee a delivery queue position. Check DOBOT's reservation terms, regional availability, and estimated delivery dates.
What sensors are reported for the Rover X1?
The profile lists the sensor descriptions below. These entries do not establish physical sensor counts, sensor fusion, redundancy, or performance. Dual vision and smart perception, Dual-vision tracking system See the sensor information section for details.
How long does the Rover X1 battery last?
Test conditions and independent verification are not established by these fields. Confirm workload, operating mode and environmental conditions before comparing runtimes. Recorded runtime: Approximately 90 minutes with standard battery; approximately 180 minutes with high-capacity battery
What AI does the Rover X1 use?
How does the Rover X1 compare to the FX Navi?
The Rover X1 and FX Navi are both quadruped robots, but they differ in key specifications, pricing, and manufacturer approach. Use the side-by-side comparison tool to see detailed differences in specs, sensors, and capabilities. You can also browse other similar robots.
What platforms or ecosystem relationships are listed for the Rover X1?
These are the platforms, communities, or ecosystem relationships listed in the profile. A listed name or protocol alone does not confirm home-device interoperability or automation support. iOS 10.0+, Android 9.0+
How current is the Rover X1 data on ui44?
The Rover X1 record has a last-checked date of 2026-06-09. Consult the model description, source links, and attribution notes for the basis of individual claims. This date does not mean every claim is manufacturer-confirmed or independently tested. If you notice outdated information, please let us know.

Data Integrity

The Rover X1 record brings together the listed specifications and attributed claims. Consult the model description and source notes to distinguish manufacturer announcements, reported information, and unknowns. A source link or review date does not establish independent testing or manufacturer confirmation of every claim. Record last checked: 2026-06-09. Official source: DOBOT official source. If you find outdated or incorrect information, please let us know — accuracy is our top priority.

Explore More on ui44

Explore more quadruped robots

See how the Rover X1 stacks up — compare specs, browse the quadruped category, or search the full database.