That matters. The home-robot bottleneck is no longer only whether a robot can talk. It is whether the robot can see a messy scene, reason about the next physical action, move safely, recover when an object slips, and do that on hardware people might actually buy or pilot.

The short version: MolmoAct 2 is good news for the field, but it is not a drop-in brain for every humanoid or home assistant. It is a stronger open foundation for manipulation research. A useful household robot still needs the right body, sensors, gripper, safety limits, service model, and home-specific training data.
What is MolmoAct 2?
MolmoAct 2 is Ai2's second-generation Action Reasoning Model, or ARM. Instead of treating robot control as a simple command-to-motion script, the model tries to reason about a scene in 3D before choosing actions. Ai2 says the release includes open model checkpoints, bimanual manipulation data, a fully open action tokenizer, and a LeRobot workflow for fine-tuning and inference.
The important buyer-facing point is not the acronym. It is the direction of travel. Robot AI is moving from polished demos and closed policies toward more inspectable systems that developers can test on real arms, real camera setups, and real manipulation tasks.
Ai2's official release highlights several numbers worth taking seriously:
- The MolmoAct 2-Bimanual YAM dataset includes more than 720 hours of robot demonstrations.
- The model can run much faster than the first MolmoAct: Ai2 reports about 180 ms for a base action call, 790 ms with adaptive depth reasoning, versus 6,700 ms for the earlier model in its benchmark setup.
- In real-world Franka-arm tests, Ai2 reports 87.1% average success across evaluated tasks, ahead of MolmoBot and Physical Intelligence's π0.5 in that setup.
- In LIBERO post-training tests, Ai2 reports 97.2% average success for MolmoAct 2 and 98.1% for MolmoAct 2-Think.
- Ai2 says Cortex AI evaluated multiple policies on bimanual tasks and MolmoAct 2 ranked first on 7 of 8 tasks.
Those numbers do not mean your future kitchen robot will suddenly clear the table. They do mean open robotics models are getting closer to the parts of autonomy that matter: spatial reasoning, bimanual coordination, action timing, and adaptation to real scenes.
Why open robot models matter for home robots
Home robots fail when the world stops matching the demo. A towel folds differently every time. A cup reflects light. A phone cable tangles. A toy rolls under a sofa. A cereal box tips over. A person walks into the room halfway through the chore.
Closed systems can still make progress, and companies like Figure, 1X, Tesla, and others are training their own stacks aggressively. The open path matters because it gives researchers and smaller robot companies a shared base to evaluate, criticize, and improve. If a model's weights, data format, tokenizer, and training recipes are visible, the field can discover whether a failure is caused by weak perception, bad action representation, poor data, mismatched hardware, or unrealistic evaluation.
For buyers, openness is not automatically a feature on the box. Most people do not want to fine-tune a policy before dinner. But open foundations can reduce the cost of getting competent manipulation onto more platforms, especially research and assistive robots where expert operators, labs, and pilot programs already exist.

That is why Hello Robot Stretch 3 is a useful comparison point. In the ui44 database, Stretch 3 is a $24,950 open-source mobile manipulator with ROS 2 and Python support, a compact home-friendly footprint, 2-5 hours of battery life, and a 2 kg payload. Stretch 4 pushes that line further with a $29,950 list price, self-charging, an 8-hour light-load runtime, and a stronger arm rated for 2.5 kg extended or 4 kg retracted.
Those are not cheap consumer appliances. But they show the kind of hardware where open robot policies can become practical first: mobile manipulators in labs, assistive pilots, and controlled home deployments where developers can collect data, tune behaviors, and measure failures.
What MolmoAct 2 can do today
The most relevant MolmoAct 2 examples are not flashy humanoid tricks. They are tabletop and bimanual manipulation tasks that look boring until you imagine them in a kitchen or care setting.
Ai2 lists tasks such as folding a towel, scanning groceries, charging a smartphone, bussing and wiping a table, putting a bowl in a sink, lifting a tray, storing cups, putting tools away, and returning lab equipment to trays. These are exactly the kinds of primitives that sit underneath useful home chores.
A robot that can fold one towel is not a laundry robot. But towel folding tests deformable-object handling. Table wiping tests force, coverage, and tool use. Charging a smartphone tests cable/port alignment and fragile-object manipulation. Grocery scanning tests object identity, orientation, and sequencing. Bowl-in-sink placement tests reach, collision avoidance, and final pose accuracy.
The release is also interesting because it includes specific deployment targets. The GitHub repository says MolmoAct 2 supports out-of-the-box deployment on SO-100/SO-101, bimanual YAM, and Franka/DROID-style setups. That is a lot more concrete than saying a model is generally good at robotics. It tells developers where the model has seen enough camera, state, and action conventions to be useful without starting from zero.
Why it is not a universal home-robot brain
Ai2 is refreshingly explicit about MolmoAct 2's current limits. The model plans a batch of 10-30 moves and executes that sequence before inferring again. That is different from continuously reacting to every slip, bump, and new obstacle in real time. Ai2 notes that if something unexpected happens mid-batch, the robot may not adjust until the next planning step, and transitions between batches can look jerky.
The second limit is embodiment. A policy trained for a Franka arm, a SO-101 arm, or a pair of YAM arms does not automatically know how to control a humanoid with legs, five-finger hands, torso motion, palm cameras, tactile skin, and different joint limits. Cameras are mounted differently. Hands close differently. Payload limits change. Latency changes. The action space changes.

That is the key caution for humanoid buyers. Unitree G1 starts at $13,500, stands 132 cm tall, weighs 35 kg, offers 23 degrees of freedom in the standard model, and can be configured with optional dexterous hands on developer-oriented versions. It is one of the most accessible serious humanoid platforms in the database, but a model trained on tabletop arms still needs G1-specific data and validation before anyone should trust it to manipulate fragile household objects.
The same is true for more home-directed humanoids. 1X NEO is listed at $20,000 for early adopters, with a soft, lightweight body and about 4 hours of battery life. Figure 03 has no public price, but the ui44 record lists tactile arrays, depth cameras, a 20 kg payload, and roughly 5 hours of battery life. Those platforms may be closer to eventual home deployment than a bench arm, but their value depends on hardware-specific learning, safety policy, and support—not just a better open model.
The home-robot readiness checklist
A model release should change your expectations only if it moves several layers of the product stack. For MolmoAct 2, the strongest evidence is at the model, dataset, and developer-tooling layers. The weakest evidence is still at the consumer-home-product layer.
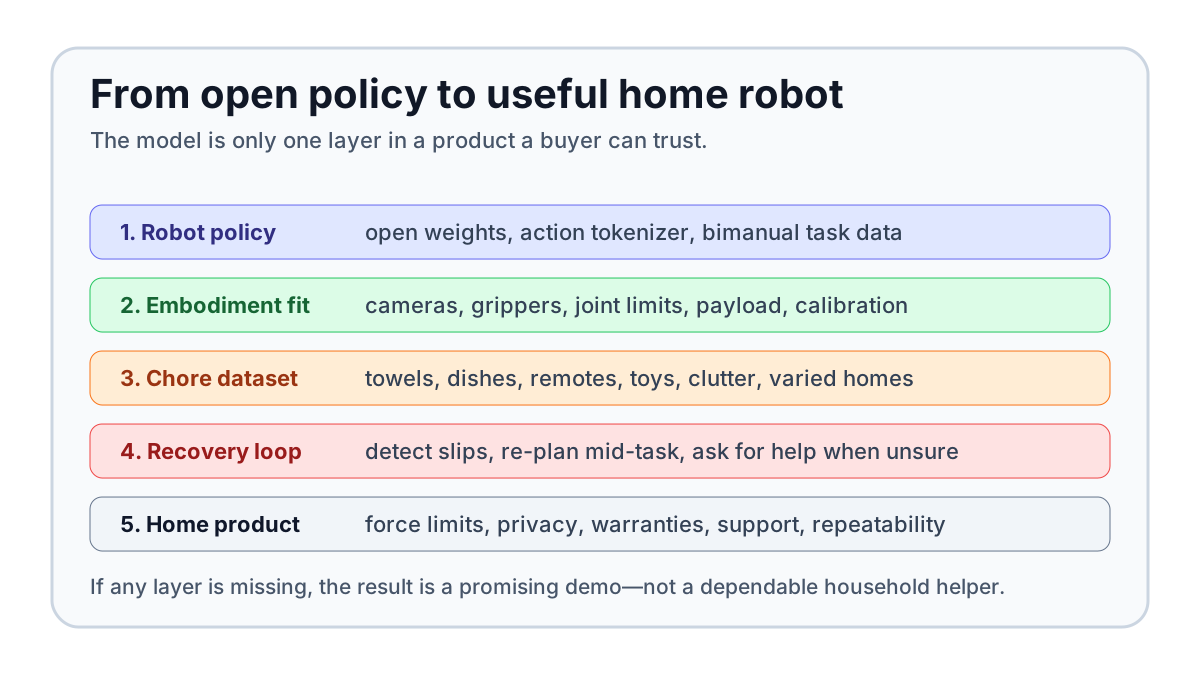
Before treating any MolmoAct-style model as home-ready, ask five questions:
Buyer question
Has it been trained on this exact robot body?
- Why it matters
- Arms, hands, cameras, torque limits, grippers, and bases change the action space.
Buyer question
Can it recover mid-task?
- Why it matters
- A home chore fails if one slip, bump, pet, or moved object breaks the sequence.
Buyer question
Does it know household objects, not just lab props?
- Why it matters
- Towels, dishes, remotes, groceries, cables, toys, and clutter behave differently.
Buyer question
What force and privacy limits are enforced outside the model?
- Why it matters
- A smart policy still needs safe hardware, emergency stops, local data rules, and supervision.
Buyer question
Who services it when the policy or hardware fails?
- Why it matters
- Home buyers need warranties, support, parts, updates, and clear accountability.
| Buyer question | Why it matters |
|---|---|
| Has it been trained on this exact robot body? | Arms, hands, cameras, torque limits, grippers, and bases change the action space. |
| Can it recover mid-task? | A home chore fails if one slip, bump, pet, or moved object breaks the sequence. |
| Does it know household objects, not just lab props? | Towels, dishes, remotes, groceries, cables, toys, and clutter behave differently. |
| What force and privacy limits are enforced outside the model? | A smart policy still needs safe hardware, emergency stops, local data rules, and supervision. |
| Who services it when the policy or hardware fails? | Home buyers need warranties, support, parts, updates, and clear accountability. |
This is where many promising systems become less consumer-ready than they look. A home robot is not only an AI benchmark. It is a machine with joints, batteries, cameras, microphones, cloud or local data flows, grippers, support obligations, and liability.
Which ui44 robots benefit most from this kind of progress?
The first beneficiaries are likely research and developer platforms. Reachy Mini, at $299 for the Lite kit and $449 for the Wireless model, is not a chore robot; it is a small open-source desktop robot for AI interaction and creative coding. But it shows how open ecosystems can make robot development more accessible. People learn tools on small robots before the same ideas reach mobile manipulators and humanoids.

ROBOTIS AI Sapiens K0 is another relevant signal. It is a 1.3 m, 34 kg open-source humanoid research platform with 23 degrees of freedom, a 3 kg max arm payload, and planned open hardware and software assets. That kind of reproducible body matters because robot policies cannot become broadly useful if every lab uses an opaque one-off machine.
Then come mobile manipulators like Stretch, which already live near the home-assistive use case. They do not need to look humanoid to benefit from better action reasoning. A wheeled robot with one reliable arm, good cameras, a cautious speed profile, and open developer tools may absorb MolmoAct-style progress sooner than a bipedal humanoid trying to solve balance, hands, and chores at once.
Finally, humanoids like Unitree G1, Figure 03, and 1X NEO benefit when open research clarifies what works. Even if those companies use their own models, open benchmarks and datasets raise the bar for evidence. A company claiming home chores should be able to show repeated trials, failure modes, recovery, hardware-specific training data, and transparent limits—not just one perfect video.
What buyers should take away
MolmoAct 2 does not make home robots ready overnight. It makes the path to useful manipulation more inspectable.
That distinction is important. If you are buying a robot in 2026, you should still judge the product in front of you: price, payload, runtime, warranty, privacy, safety, service, and what the robot can do repeatedly without a developer in the room. Do not pay consumer money for a research model unless you are comfortable being part of the research.
But if you are tracking when home robots become genuinely useful, MolmoAct 2 is a positive sign. It shows that open robot AI can now carry more of the hard manipulation stack: spatial reasoning, bimanual data, action tokenization, and practical deployment workflows. The next test is whether those foundations move from tabletops and lab arms into home-shaped robots that can recover, ask for help, and safely complete boring chores again and again.
For now, the honest answer is: MolmoAct 2 can help teach home robots. It just cannot replace the home, the robot body, or the boring validation that makes a helper worth trusting.
Sources & References
- Ai2: MolmoAct 2: An open foundation for robots that work in the real world
- GitHub: allenai/molmoact2 official repository
- Robotics & Automation News: Ai2 releases MolmoAct 2 open robotics model for real-world automation
- ui44 robot database records for Hello Robot Stretch 3, Hello Robot Stretch 4, Reachy Mini, Unitree G1, ROBOTIS AI Sapiens K0, Figure 03, and 1X NEO
Written by
ui44 Team
Published May 26, 2026
Share this article
Open a plain share link on X or Bluesky. No embeds, no widgets, no cookie baggage.